भारतीय प्रौद्योगिकी संस्थान रुड़की
INDIAN INSTITUTE OF TECHNOLOGY ROORKEE
Intelligent Computing and Complex Networks Lab • Directed by Dr. Neetesh Kumar & Dr. Pardumen Pandey | IIT Roorkee
Comprehensive research infrastructure supporting autonomous driving, UAV swarms, edge-AI, and V2X communication
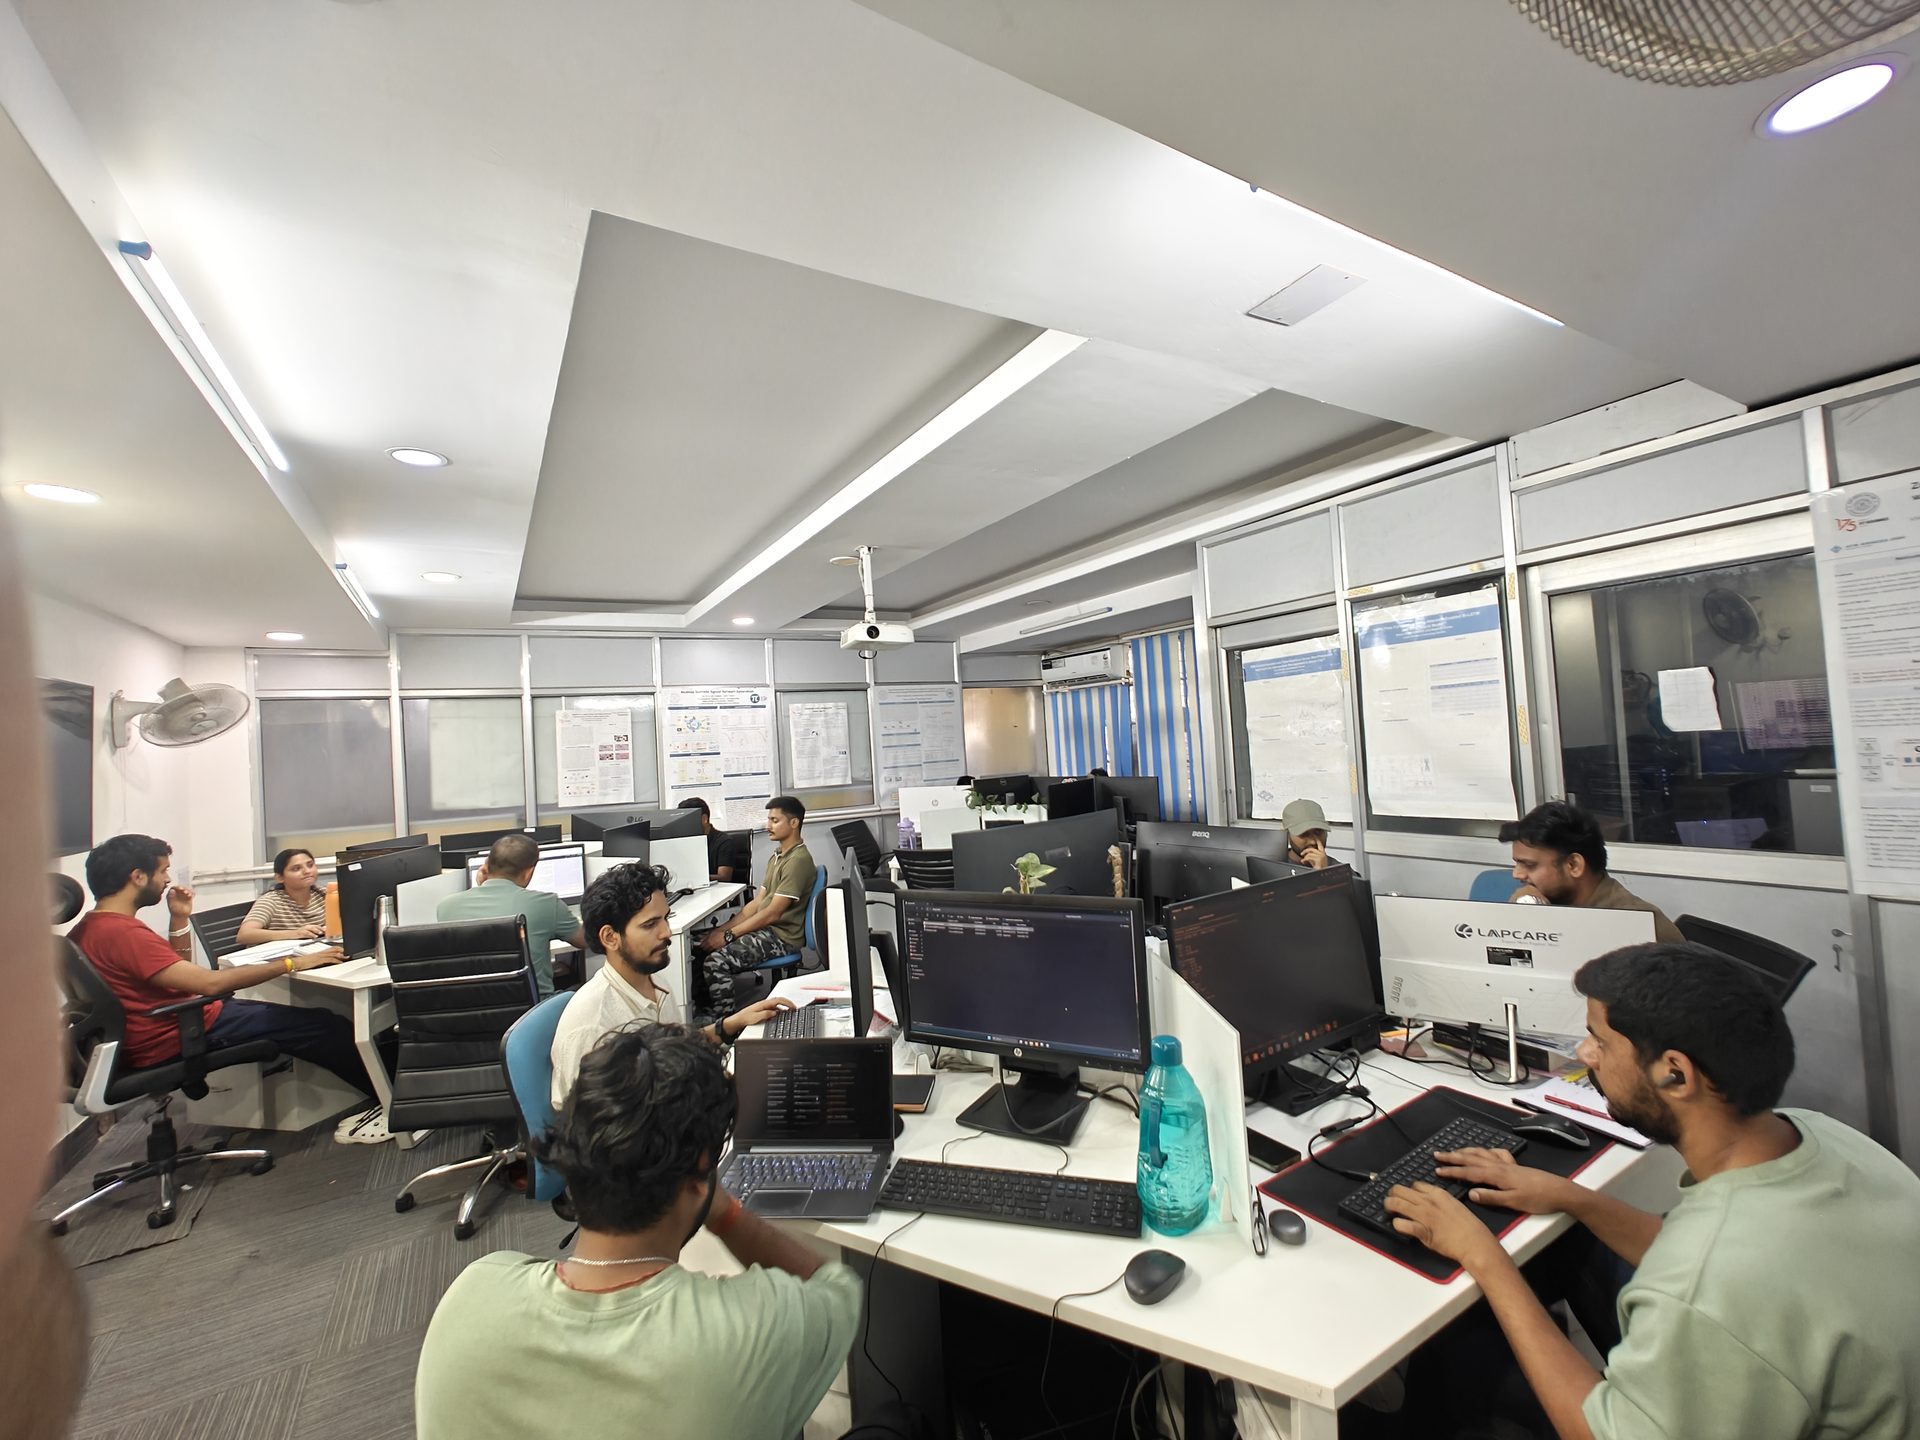
Active collaborative research space of the Intelligent Computing and Complex Networks Lab (ICCN Lab) at IIT Roorkee under Dr. Neetesh Kumar and Dr. Pardumen Pandey, equipped with high-end multi-display workstations, edge-hardware testbenches, and prototype testing stations.
View in Gallery →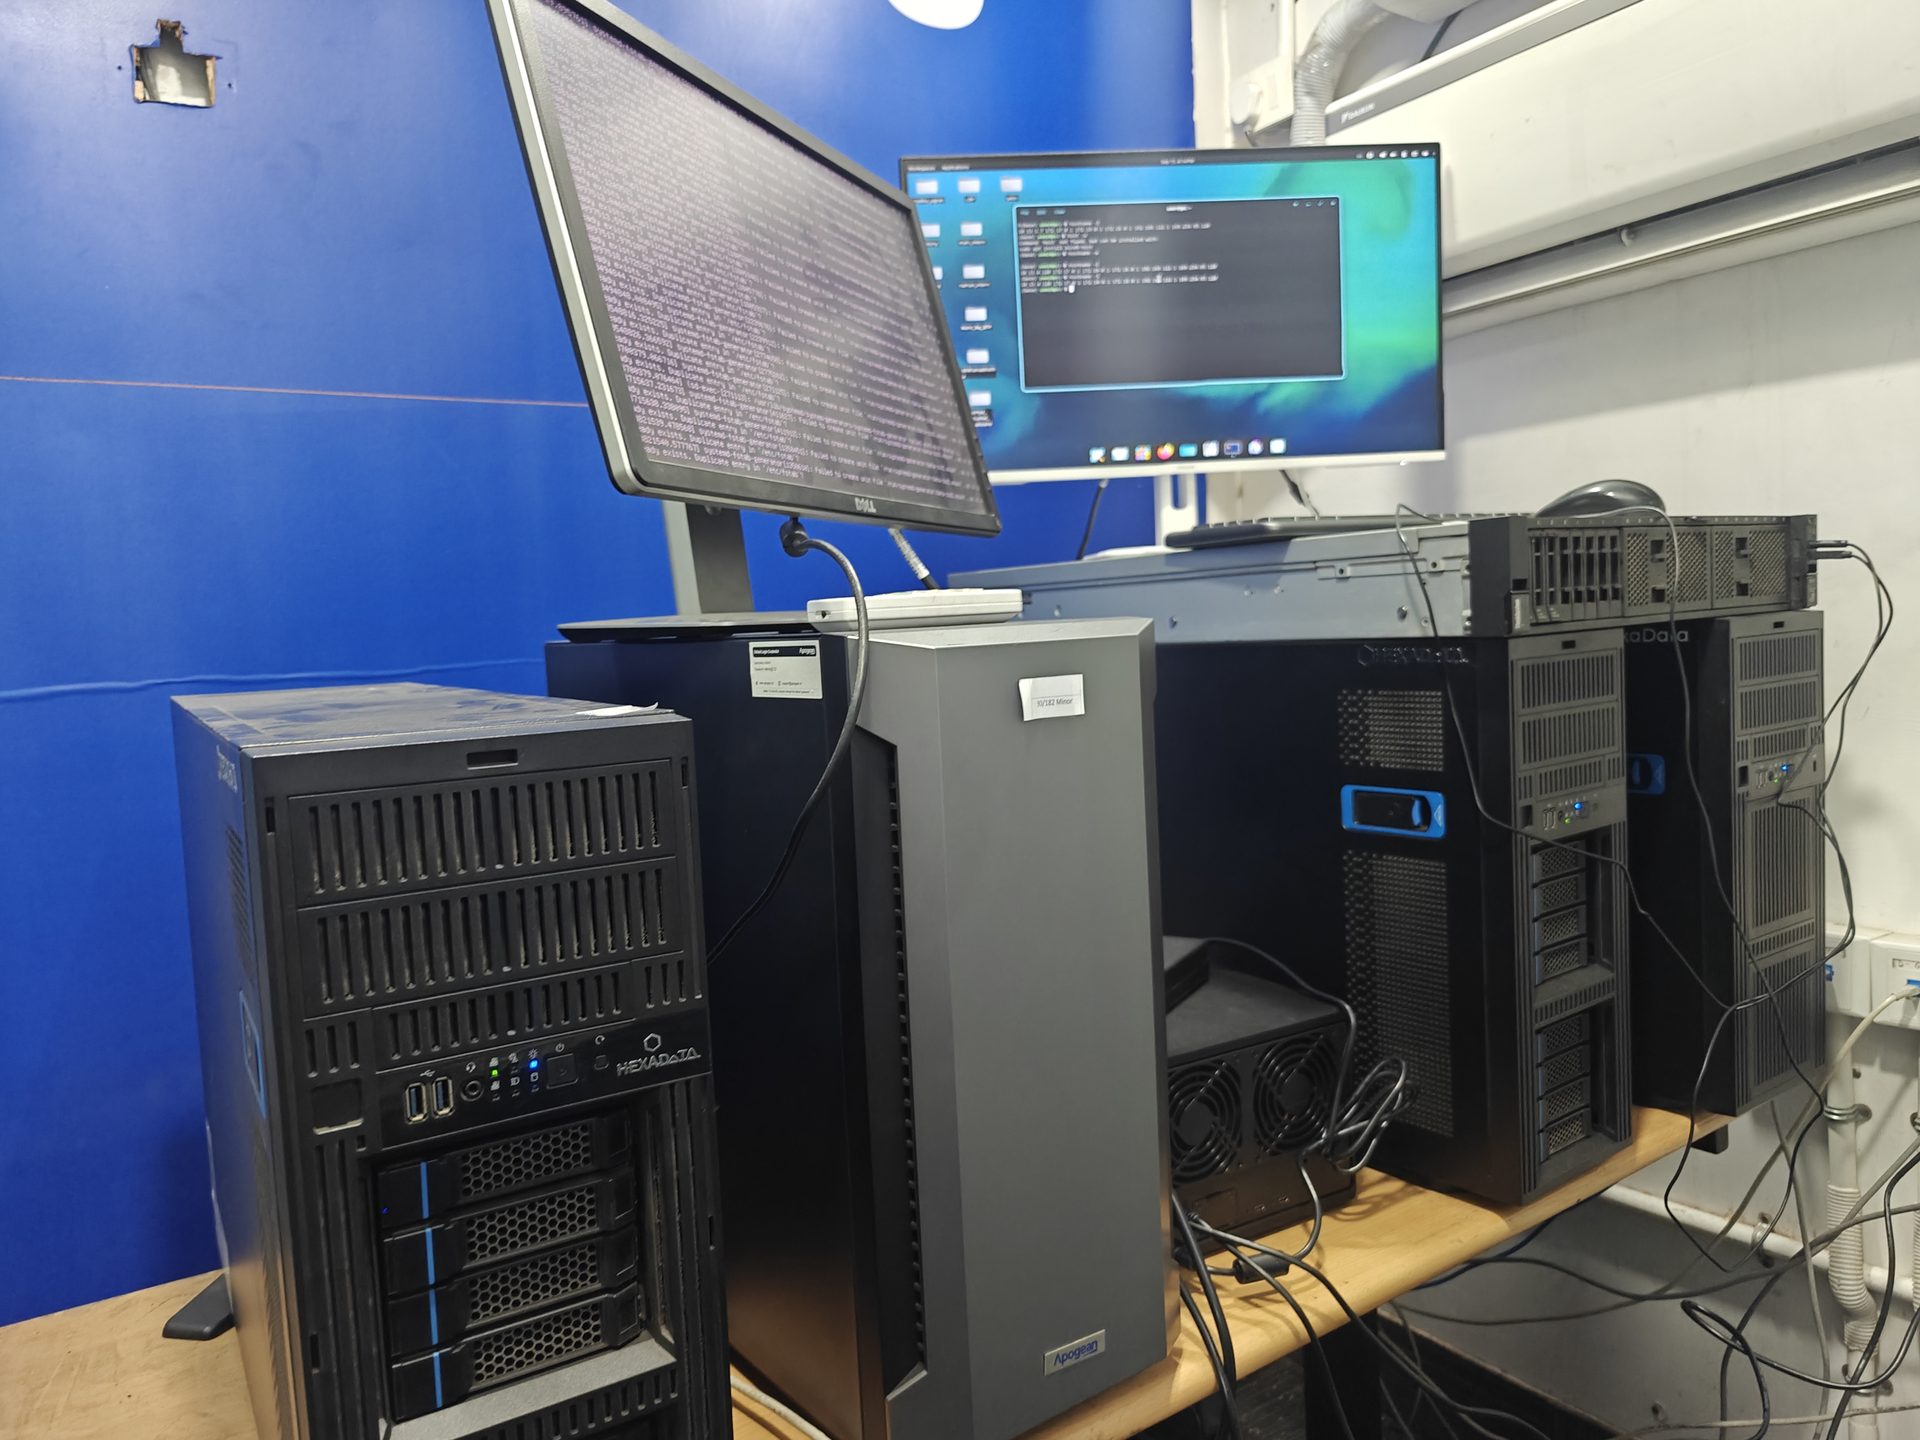
Dedicated multi-GPU rackmount and tower server cluster accelerating deep learning, reinforcement learning models, and complex vehicular network simulations.
View in Gallery →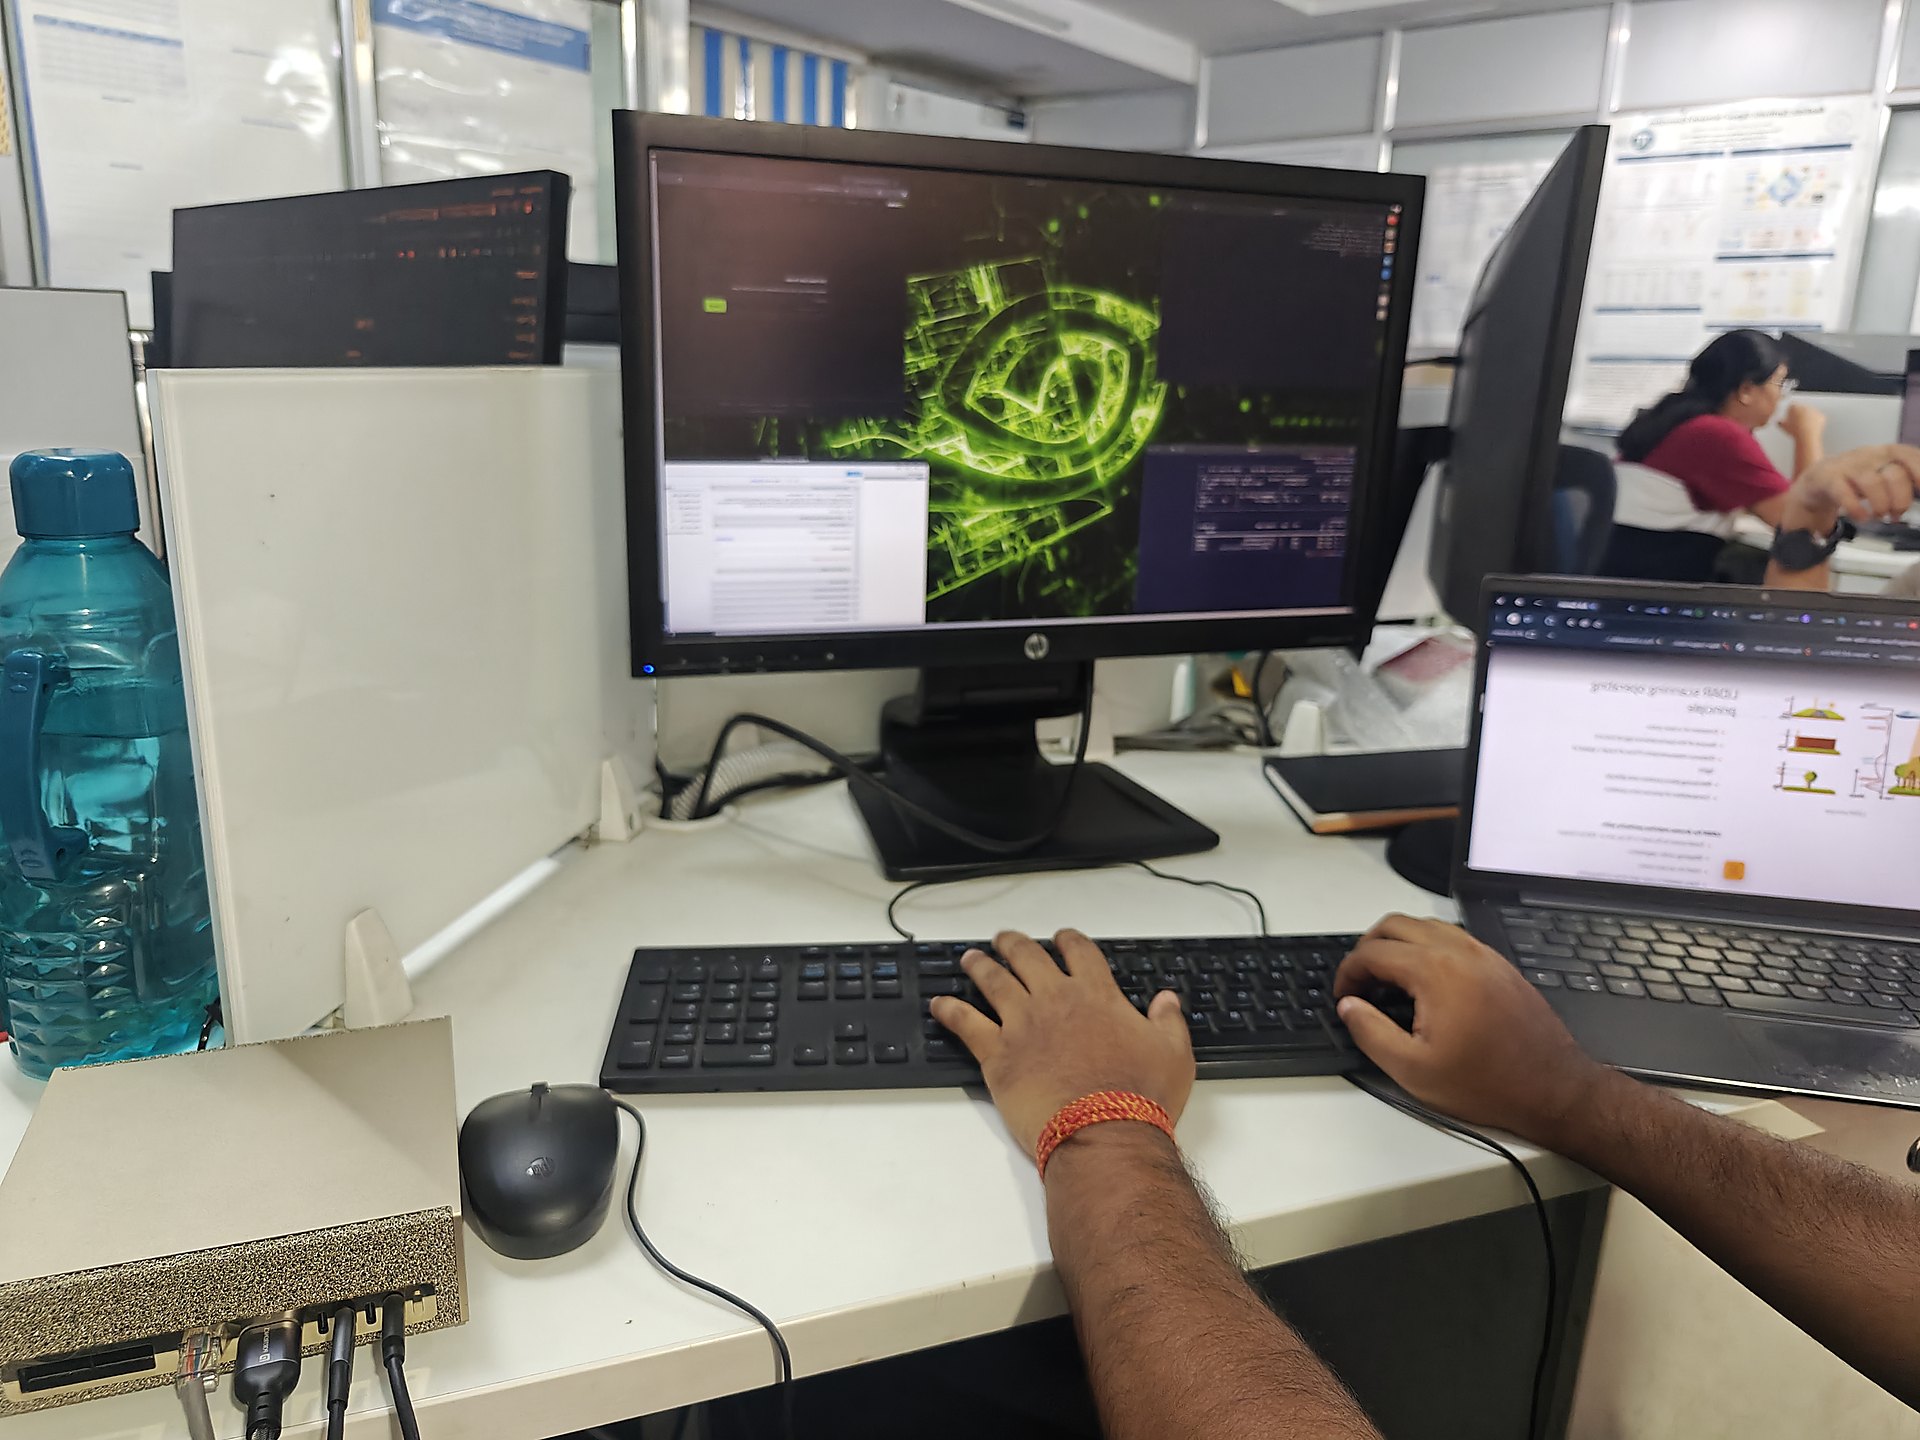
Embedded edge-computing system running real-time LiDAR point-cloud processing, sensor fusion, and low-latency computer vision algorithms for autonomous mobility.
View in Gallery →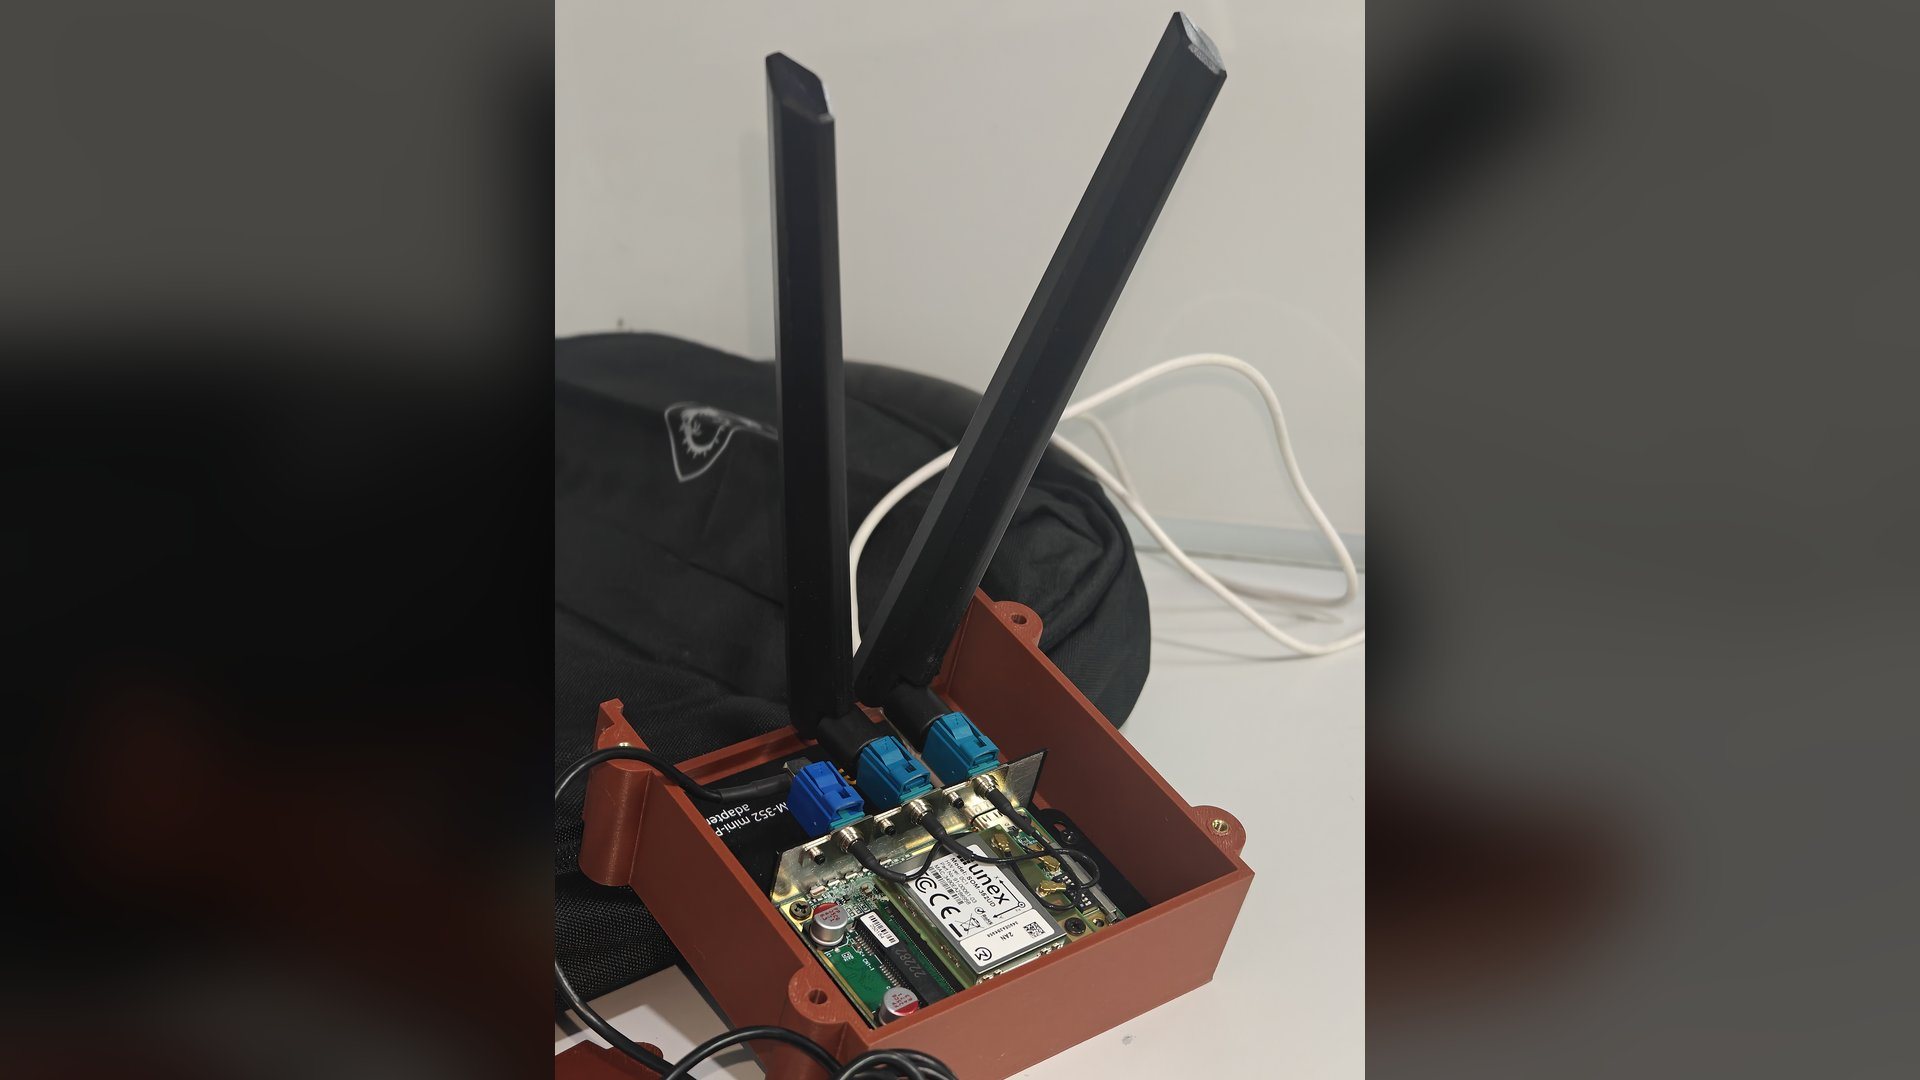
Unex C-V2X / DSRC transceiver hardware rig with high-gain dual antennas in a custom enclosure for Vehicle-to-Infrastructure (V2I) and Vehicle-to-Vehicle (V2V) field experiments.
View in Gallery →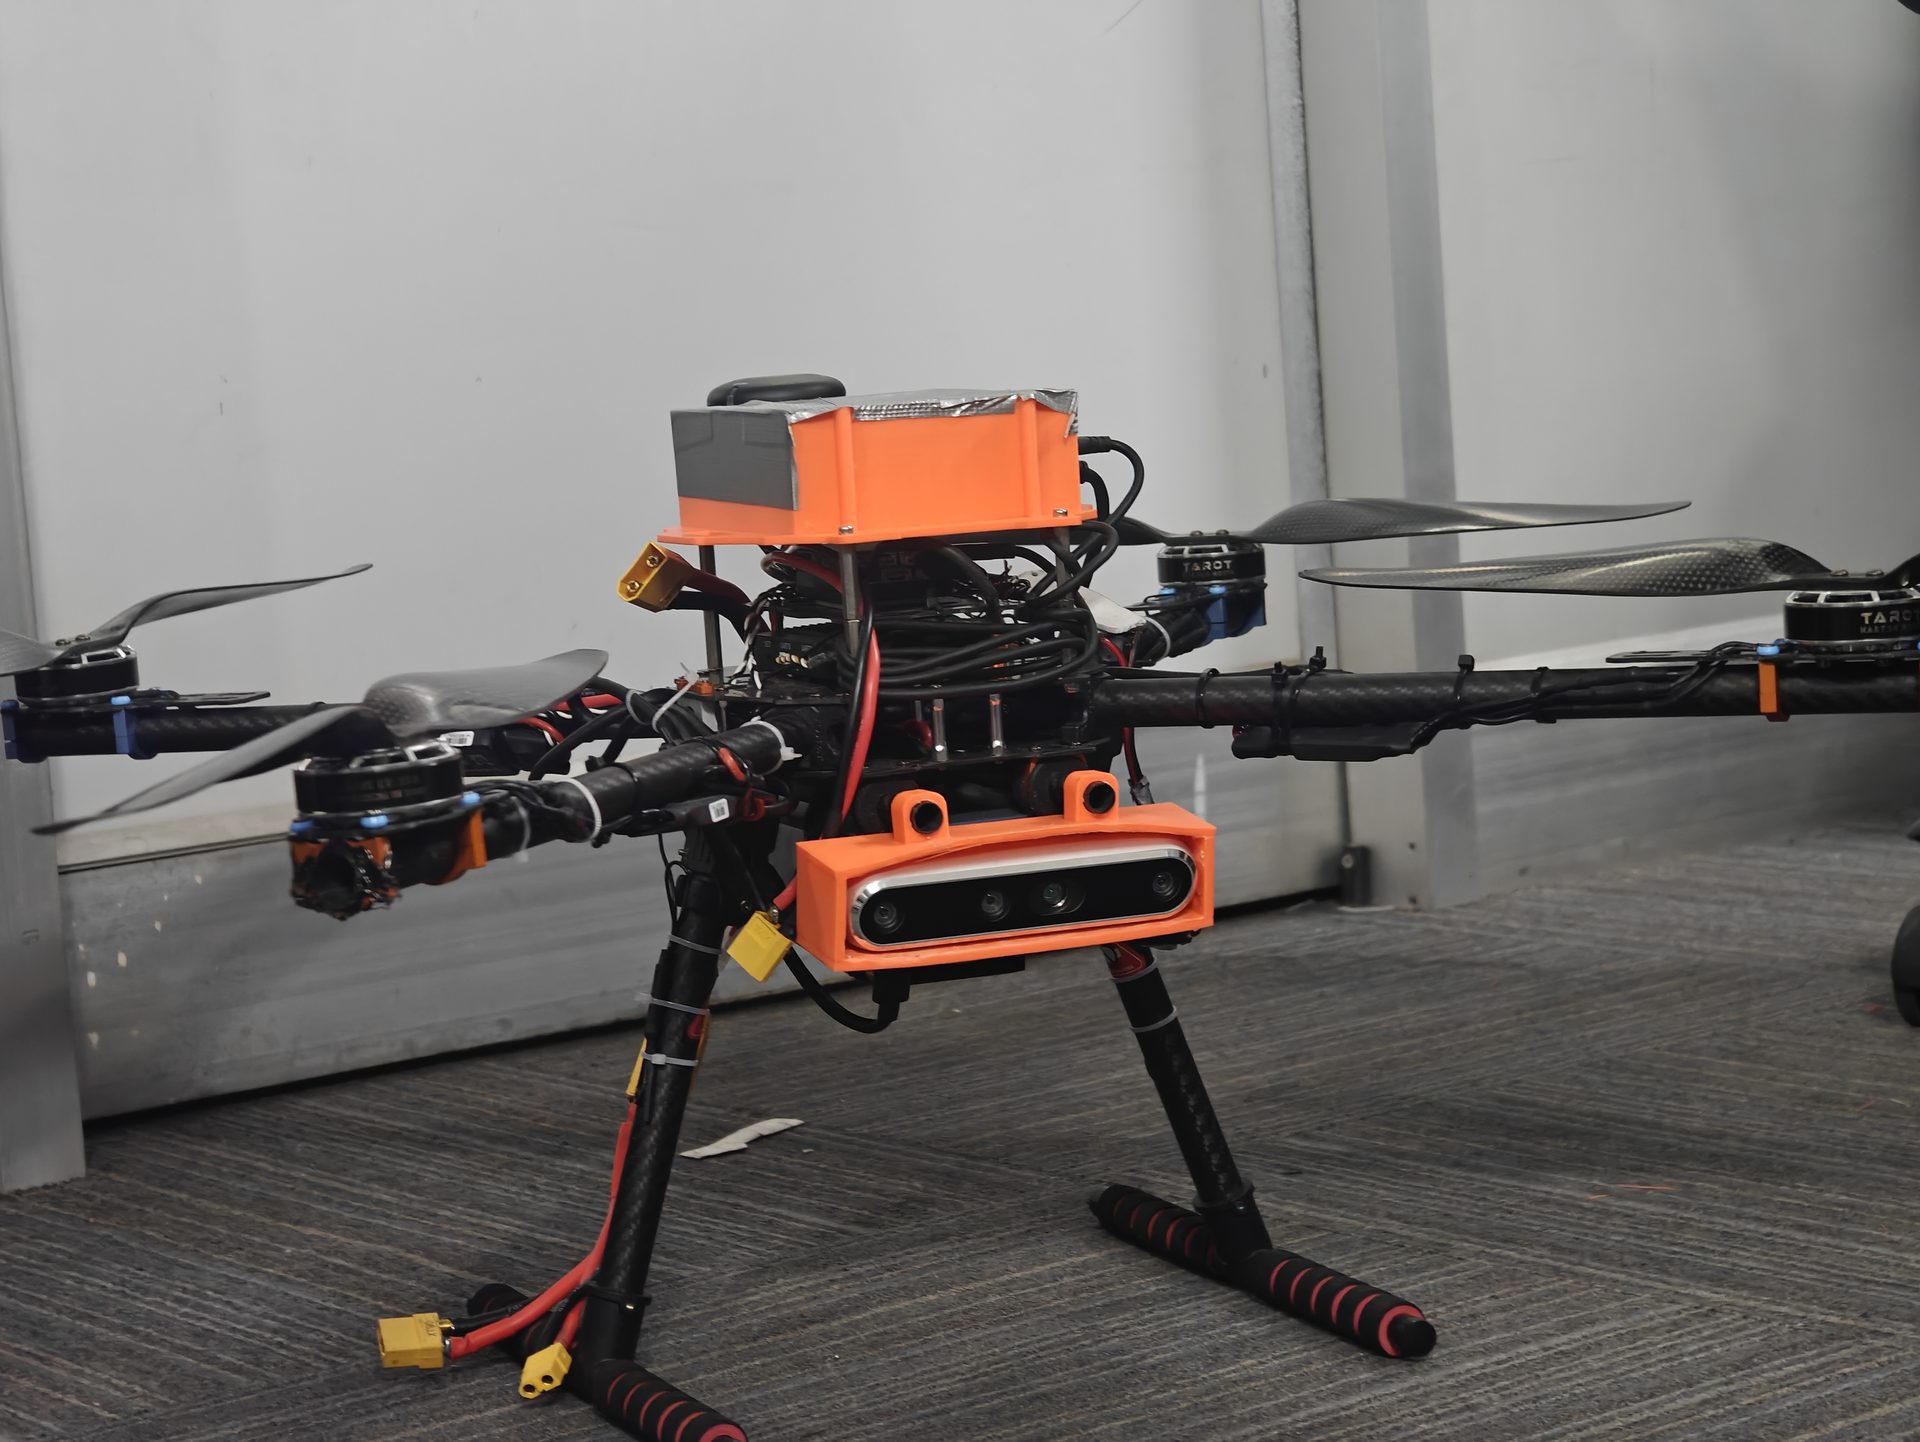
Custom heavy-lift quadcopter integrated with an Intel RealSense depth camera and companion computer for real-time 3D mapping and GPS-denied navigation.
View in Gallery →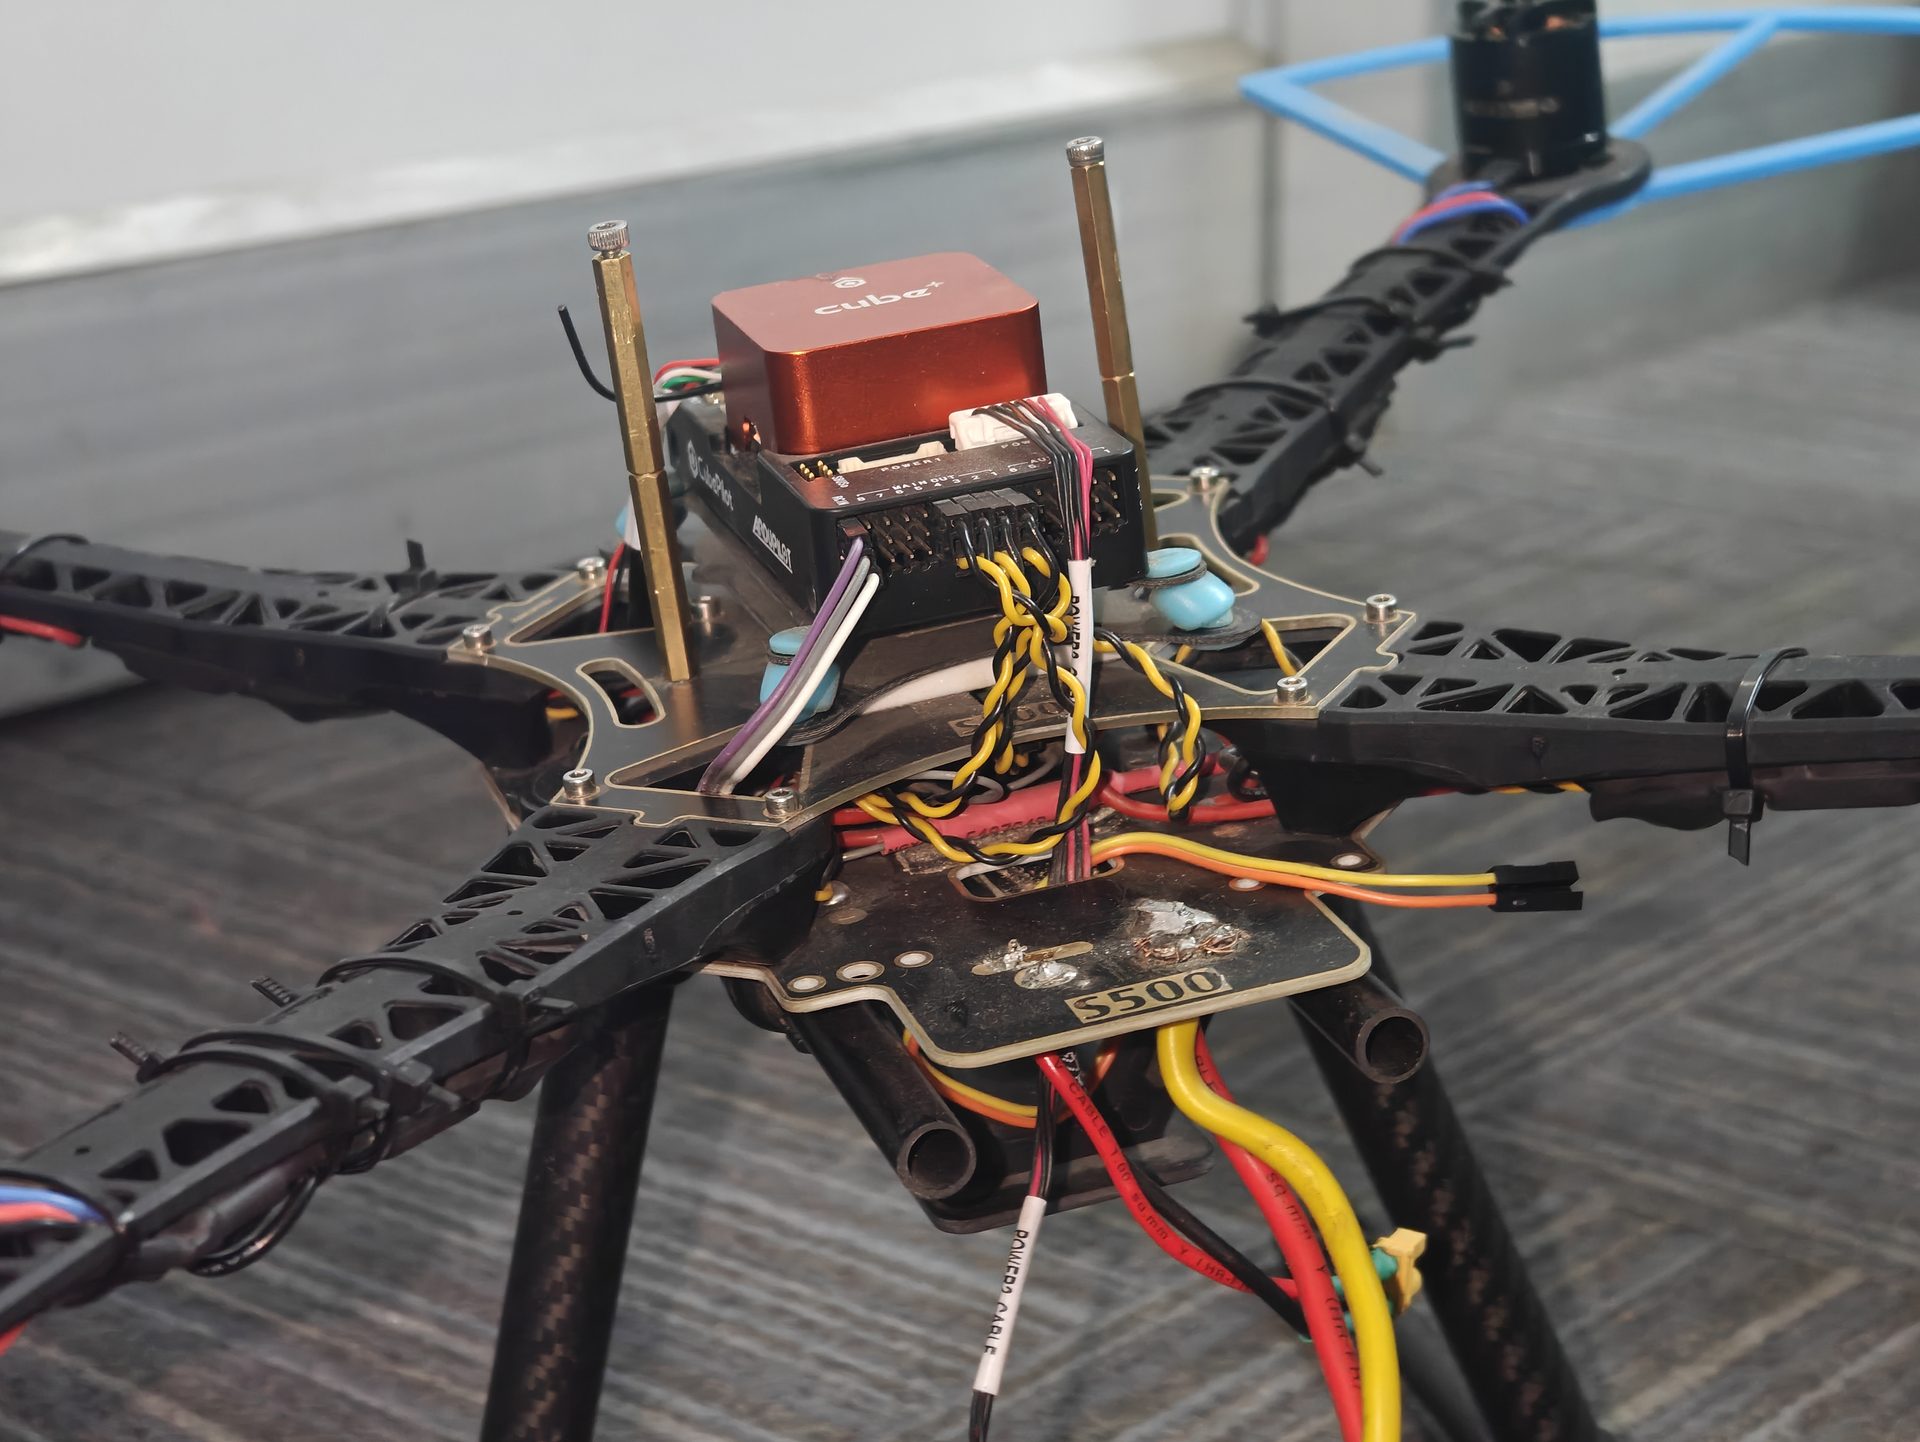
S500 quadcopter airframe equipped with a Pixhawk Cube flight controller and telemetry unit for precise autonomous waypoint mission execution.
View in Gallery →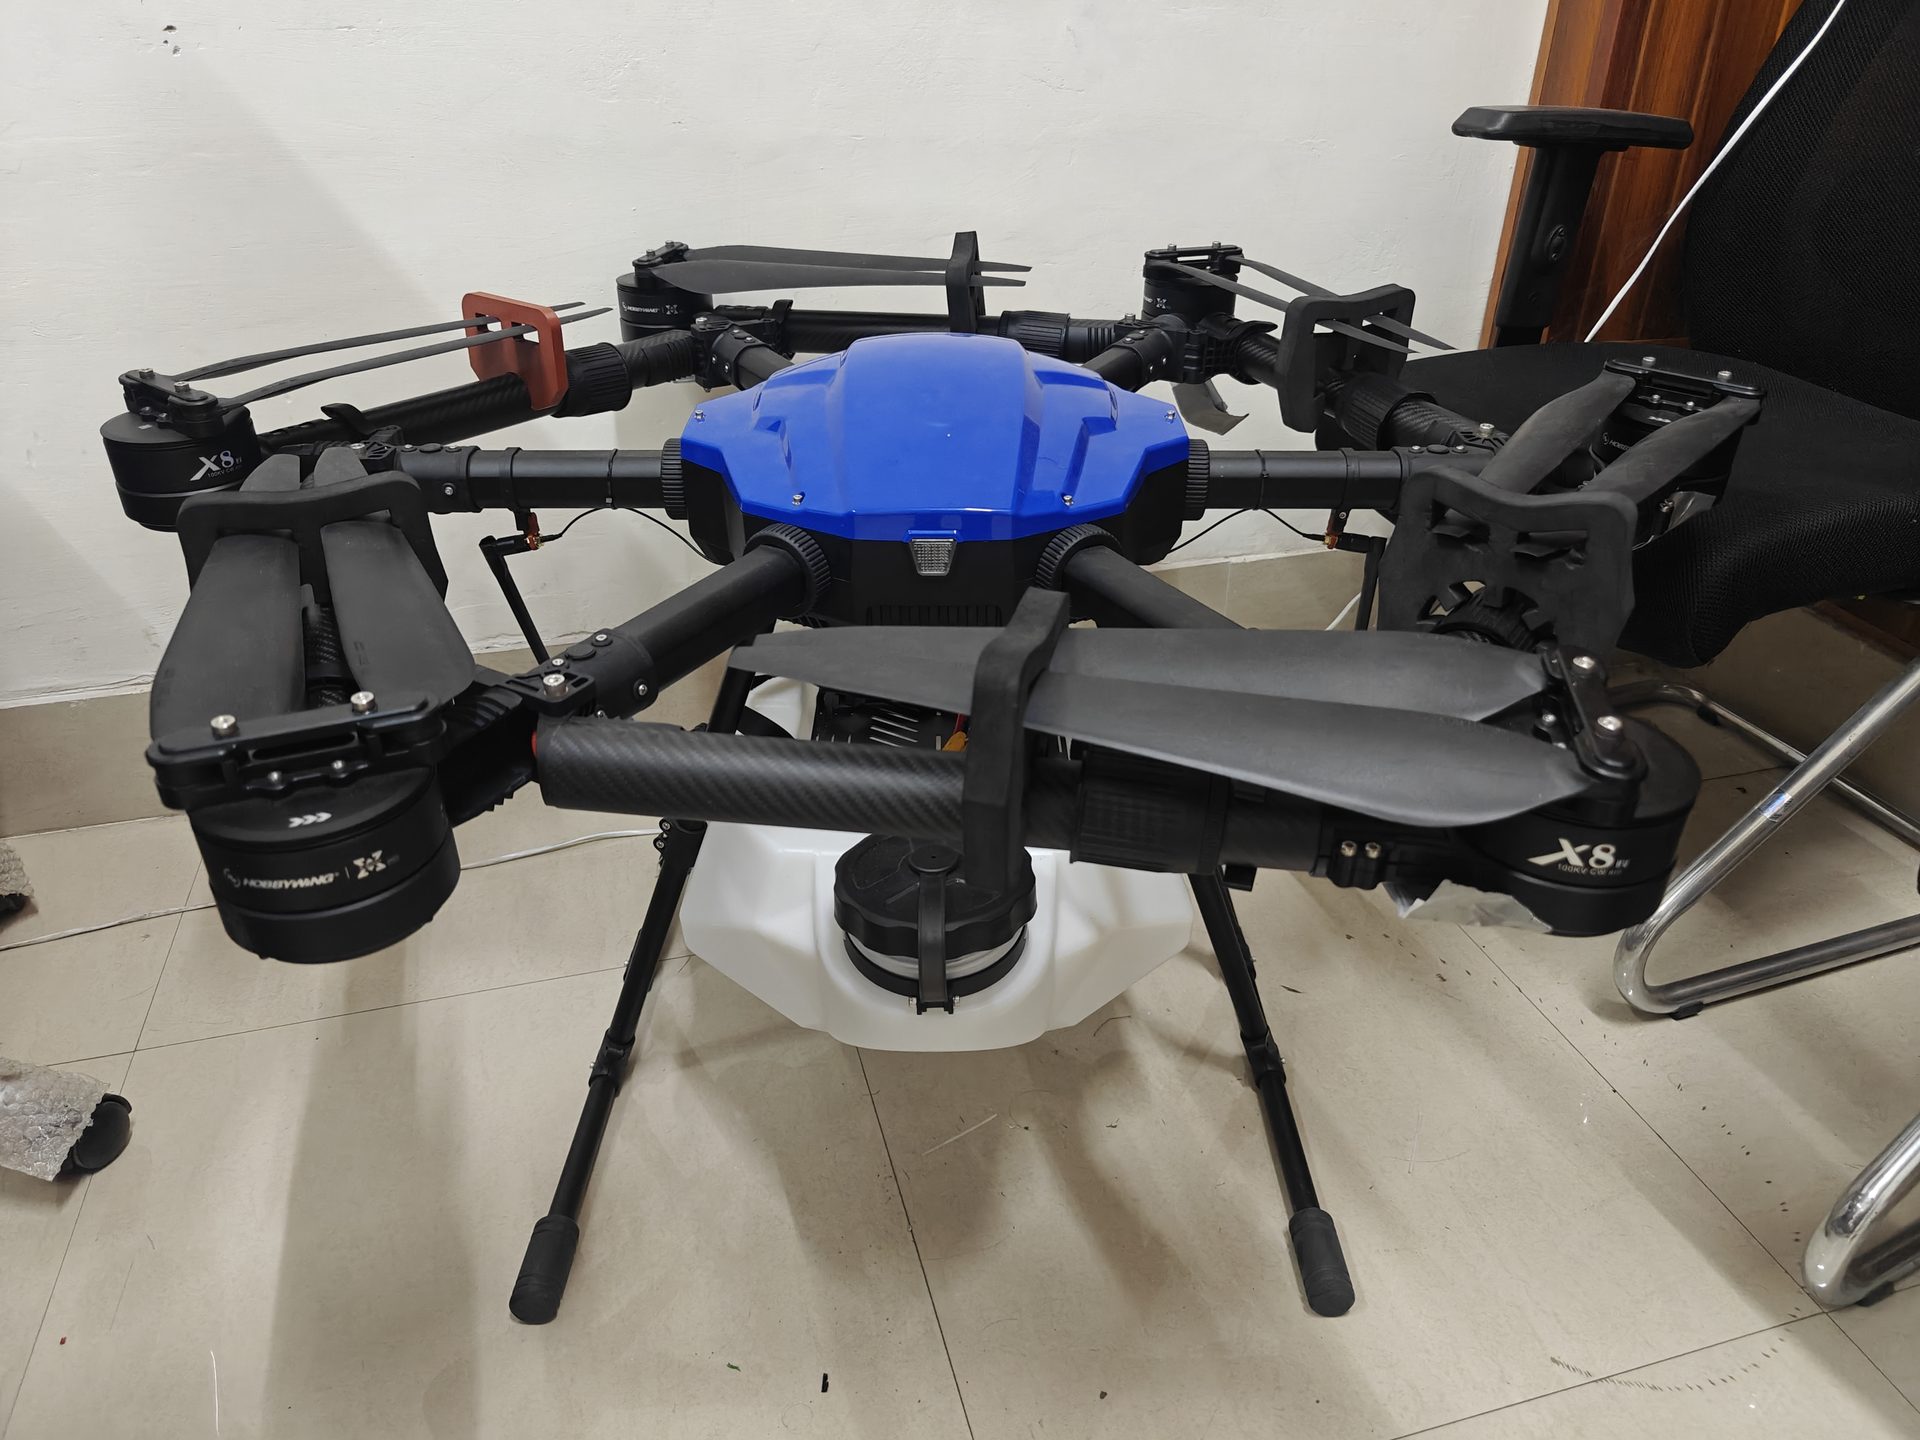
Heavy-duty multi-rotor aerial platform with Hobbywing X8 high-thrust propulsion systems for large sensor payloads and aerial surveillance experiments.
View in Gallery →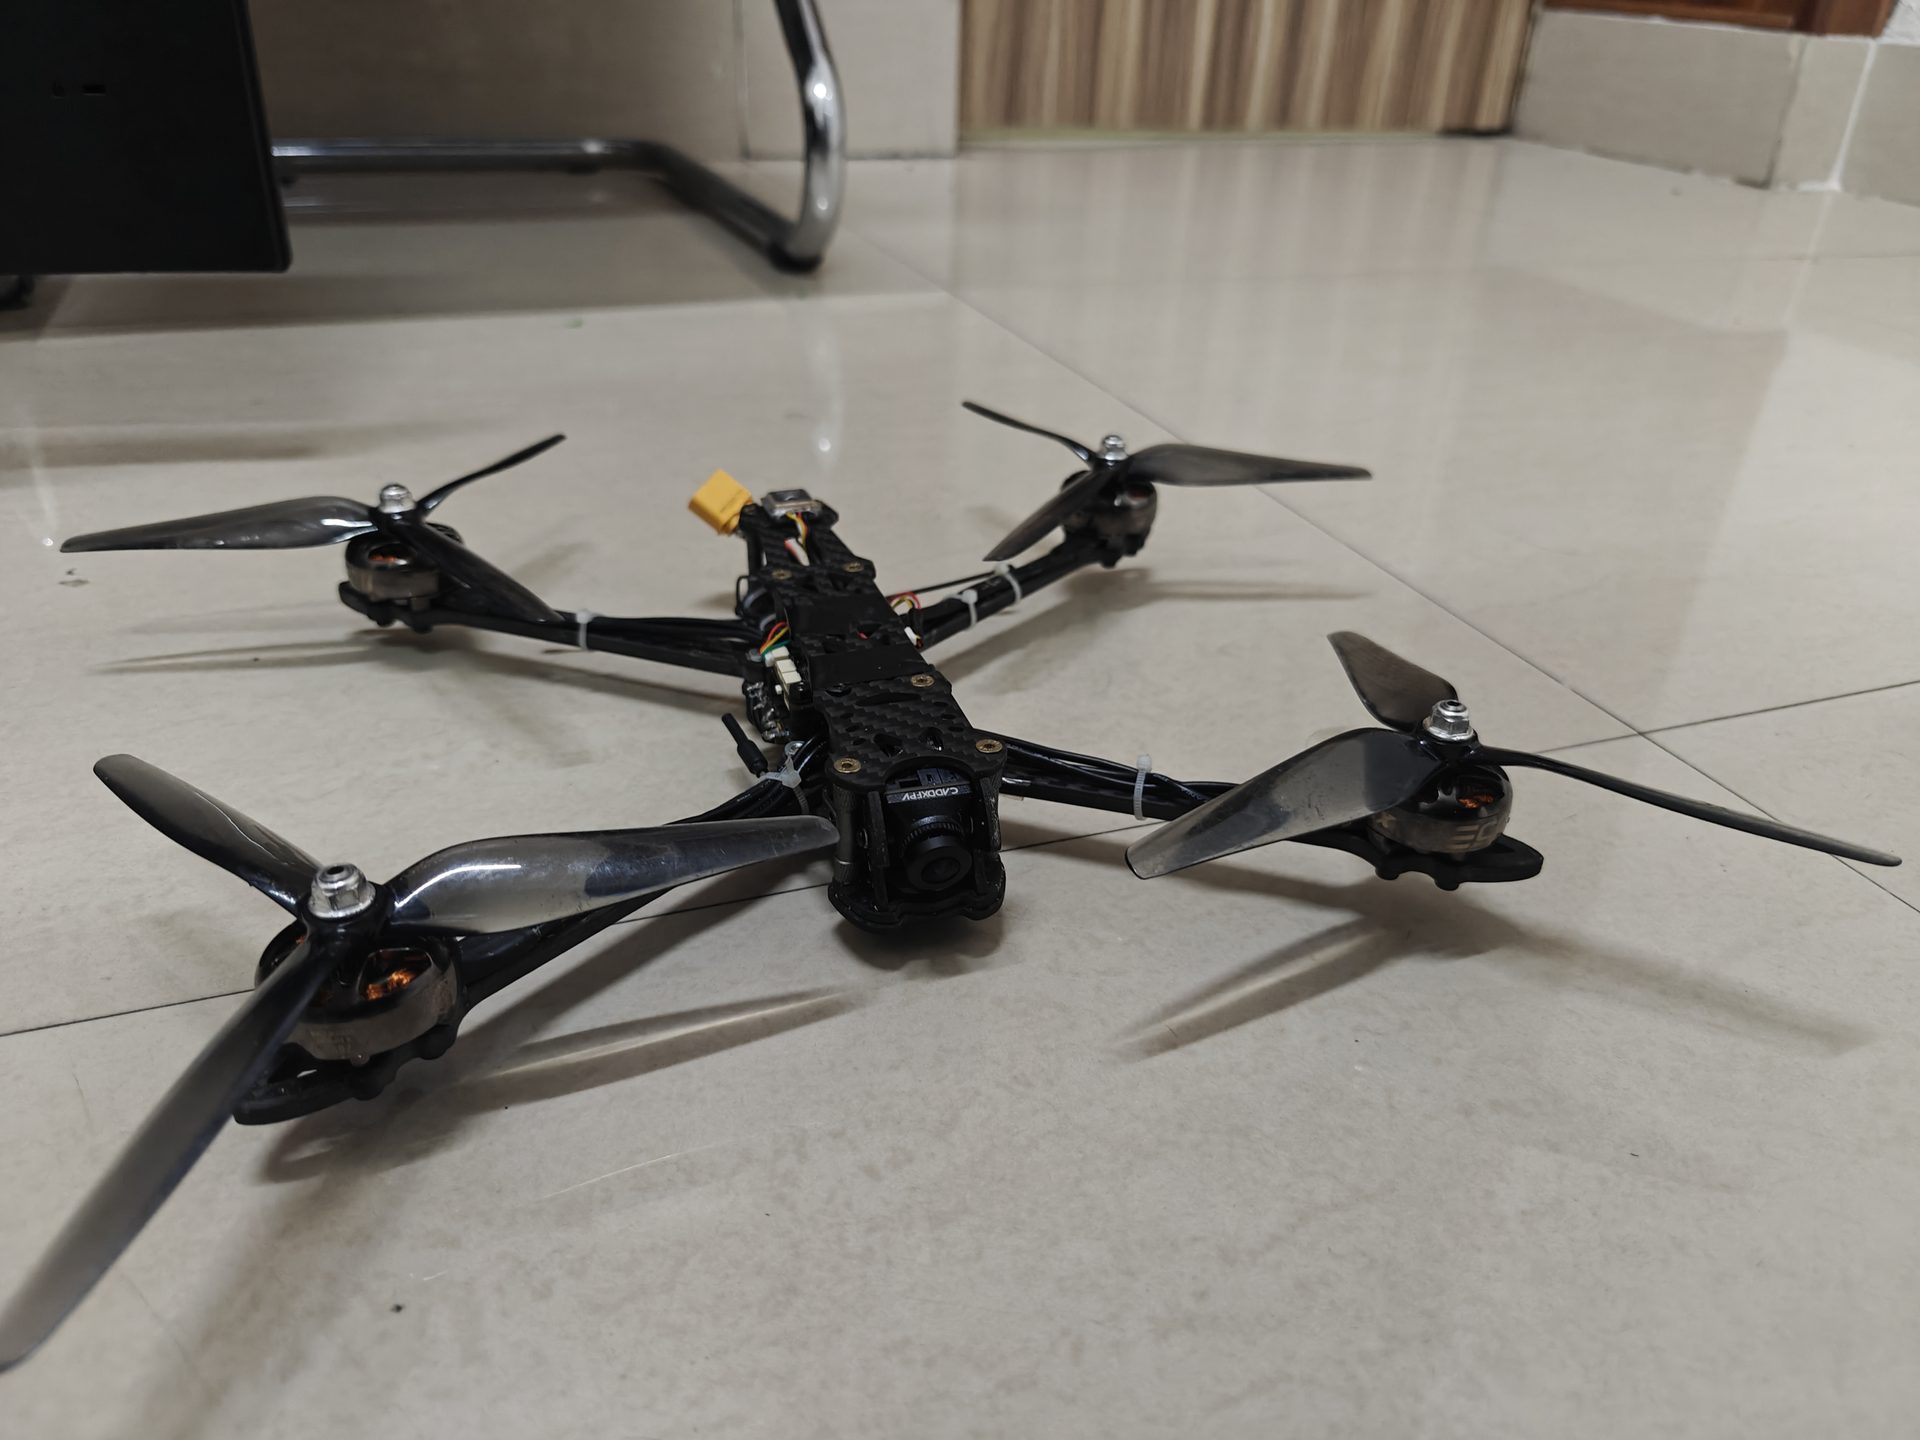
Ultra-lightweight carbon-fiber multi-rotor racing platform engineered for agile maneuvering, rapid obstacle avoidance, and dynamic aerial tracking.
View in Gallery →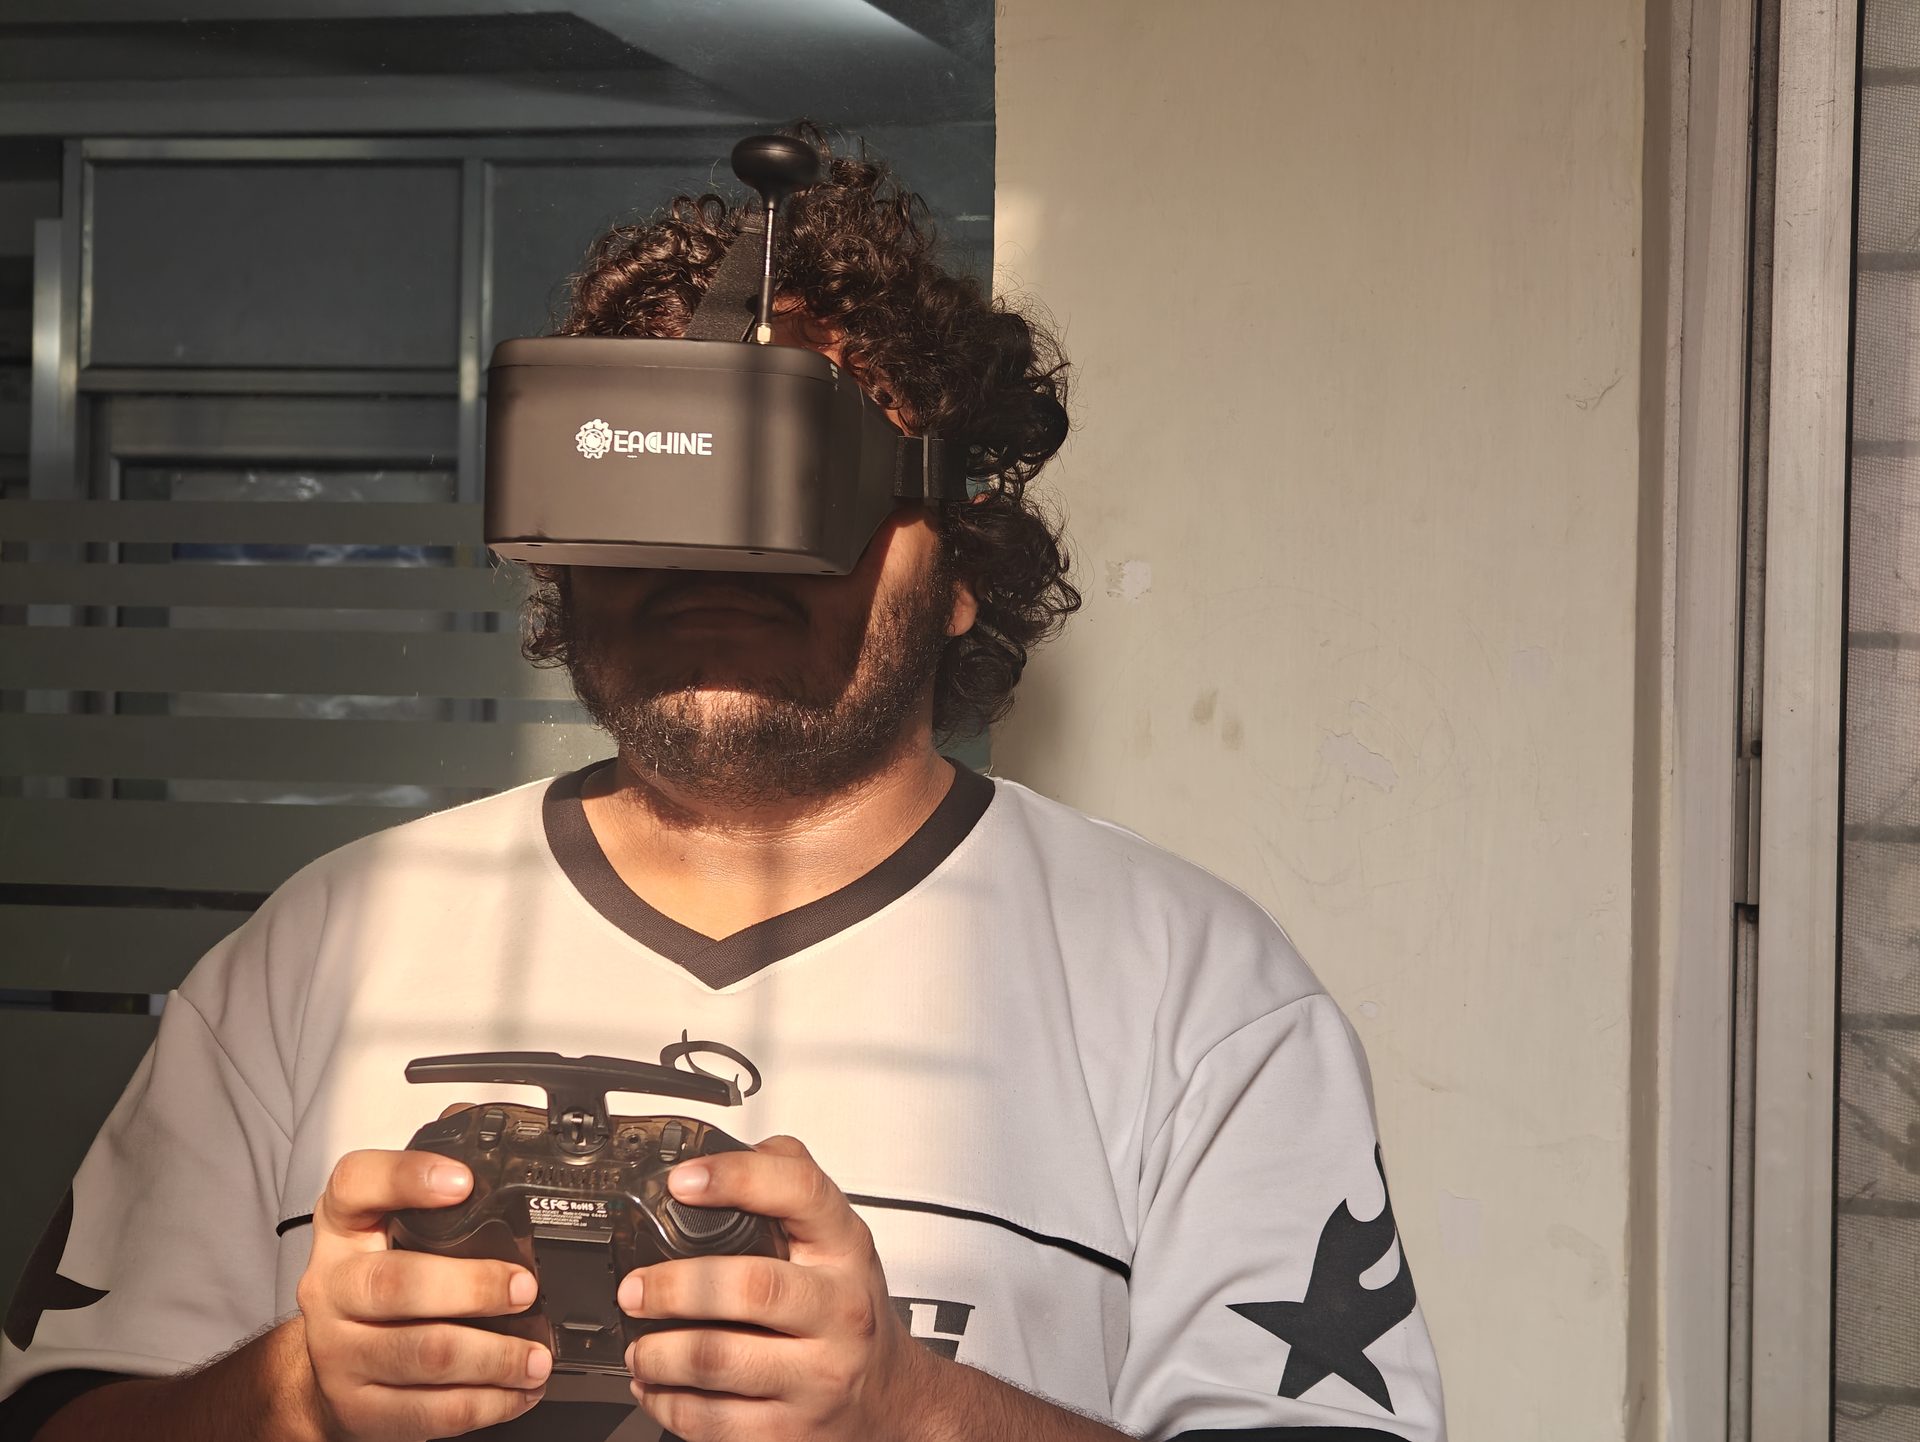
First-Person View (FPV) pilot headset and remote telemetry controller enabling real-time low-latency video feed and manual flight validation.
View in Gallery →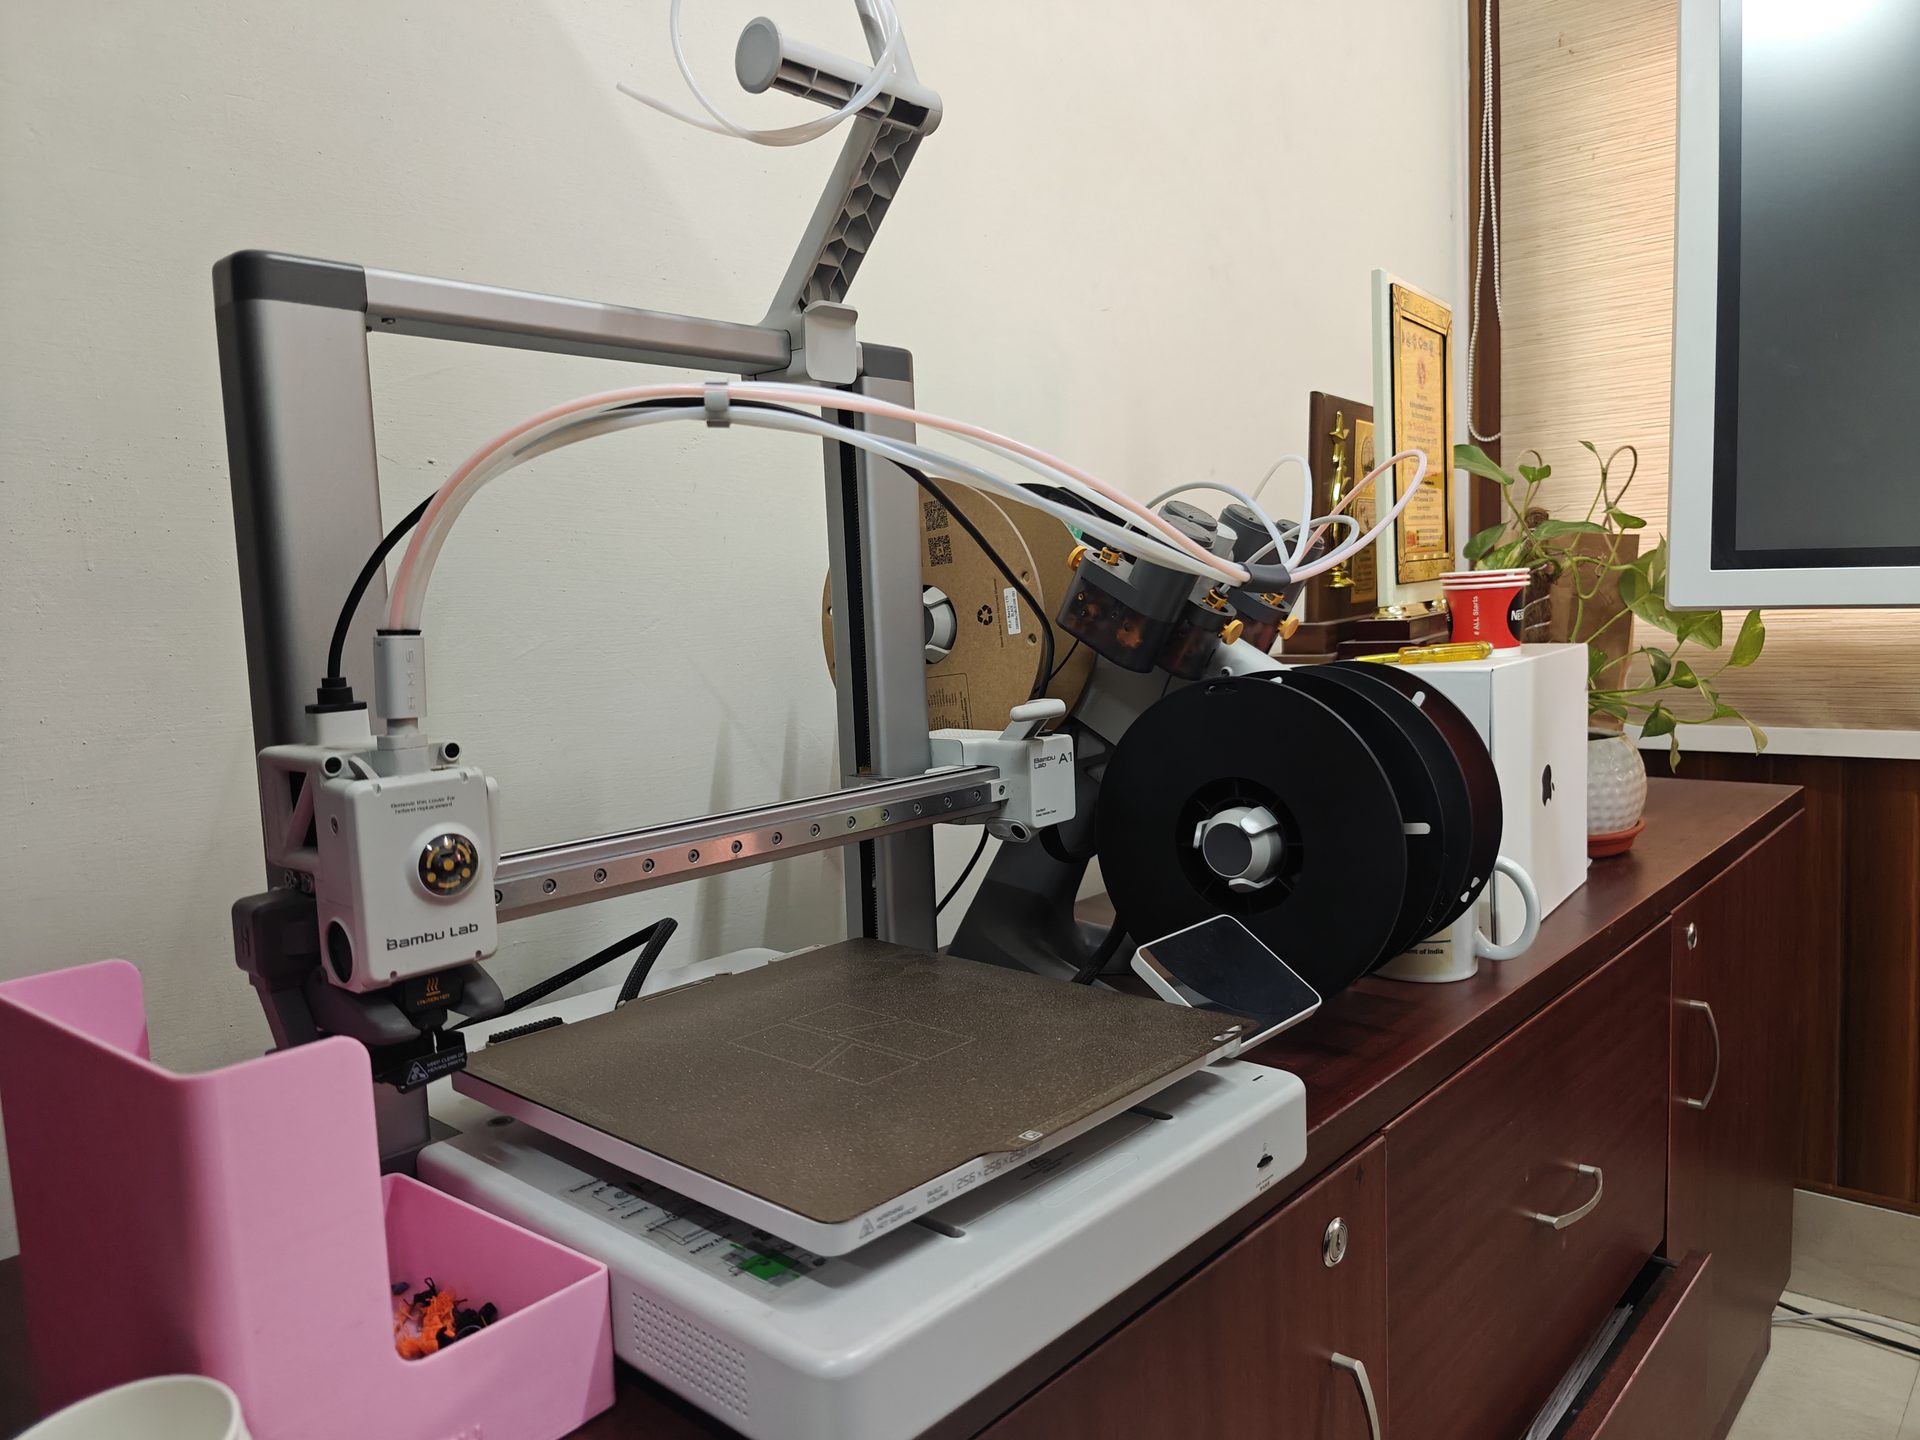
High-precision Bambu Lab 3D printer with multi-filament AMS for on-demand fabrication of custom drone mounts, sensor brackets, and robotic enclosures.
View in Gallery →